10 frames4 domainsFrame numbers match the home strip
Projects and work
Grouped by domain rather than by date. Each card leads to a page that says what the thing does, the decisions behind it, and what is missing. Press / to search inside all of them.
Production AI and evaluation
-
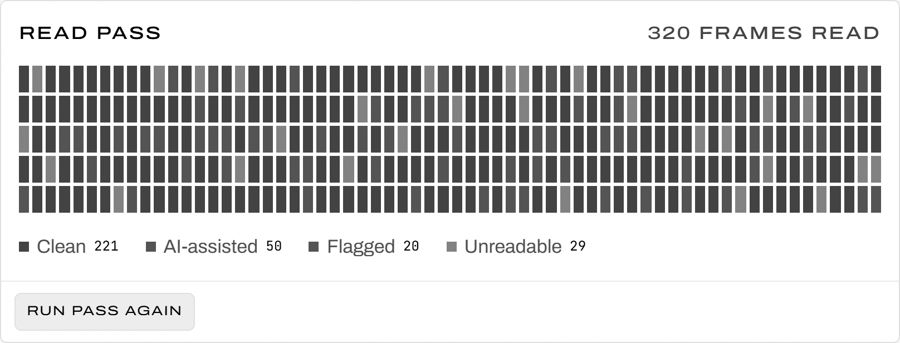 80% precision and recall, 264 sessions
Vision-LLM audit pipeline and annotation platform
A vision-LLM audit pipeline that seals recomputable ledgers, the core of an LLM annotation platform, an LLM-judge verifier, and SOC 2 Type II in a live audit. My work at Verita AI, with the bugs found on the way. Case study -
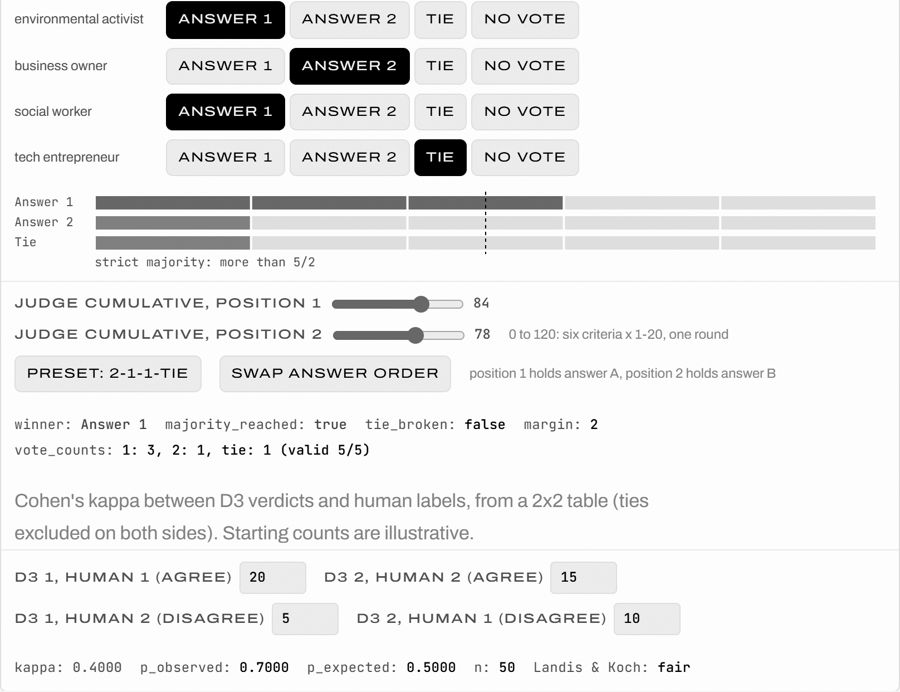 n = 20, reported with its n
Project D3
A D3 debate-judge reimplementation: every agent call carries a success flag, juror votes are range-checked and retried, and a verdict needs a strict majority. Case study -
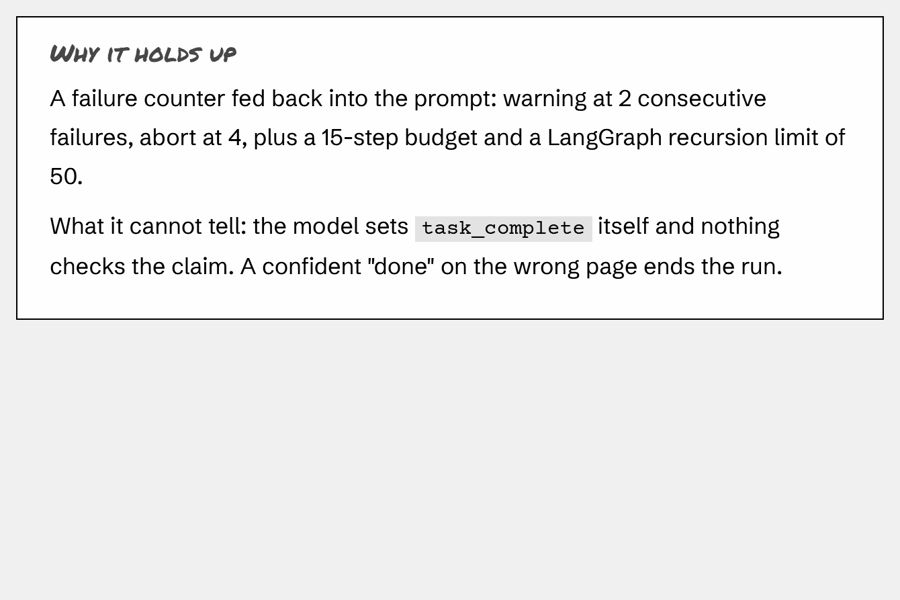
Browser Autopilot
A LangGraph and Playwright agent whose model names a credential it never sees, and whose second agent writes each run up as a screenshot tutorial. Read more -
Frontier-model evaluation
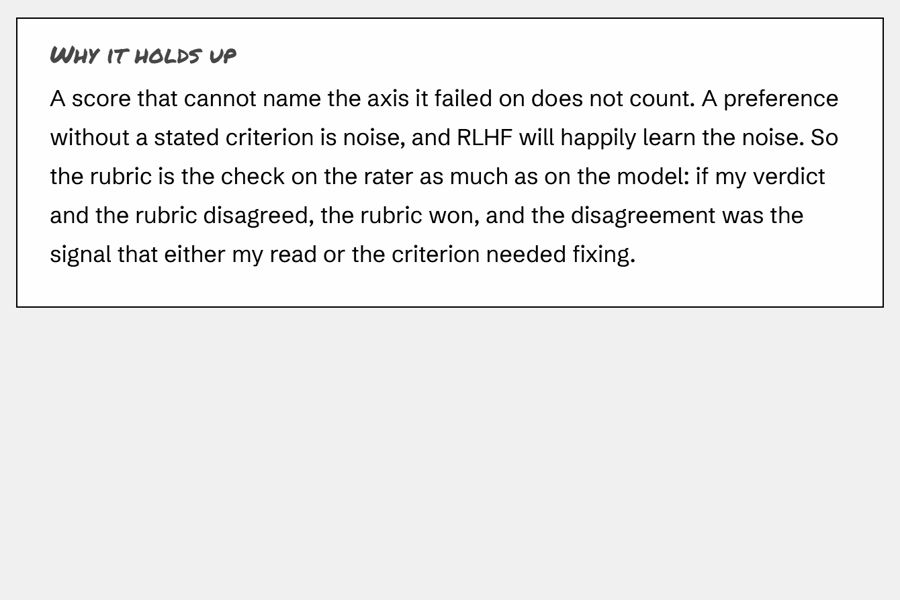
Calibrated rubric evaluation of frontier image-generation models for RLHF preference data, and a Star Fellow program probing model reasoning. My work at Handshake AI. Case study
Correctness and security
-
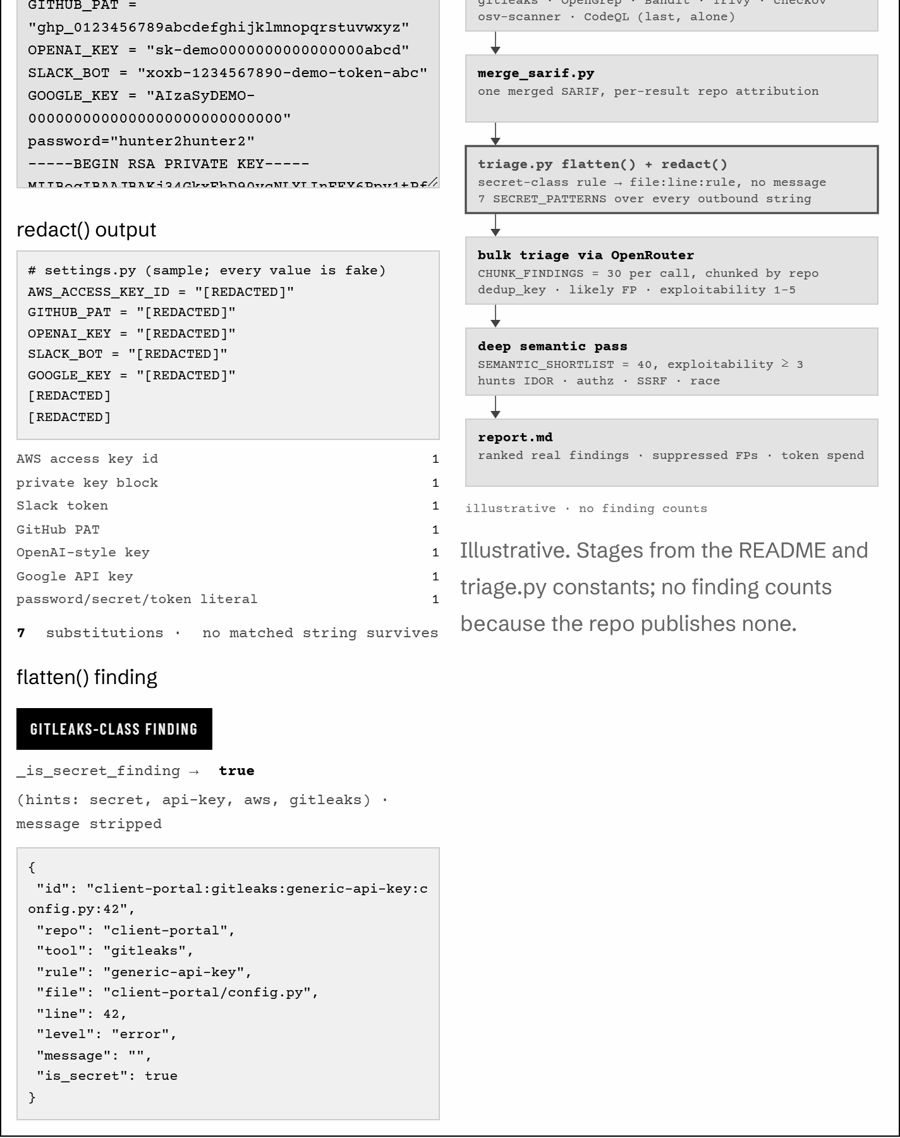 7 scanners, one SARIF, no secret shown to the model
Multi-scanner security audit with LLM triage
Seven pinned scanners on a self-terminating EC2 box, merged to one SARIF and triaged by a reasoning model that is never shown a secret. Case study -
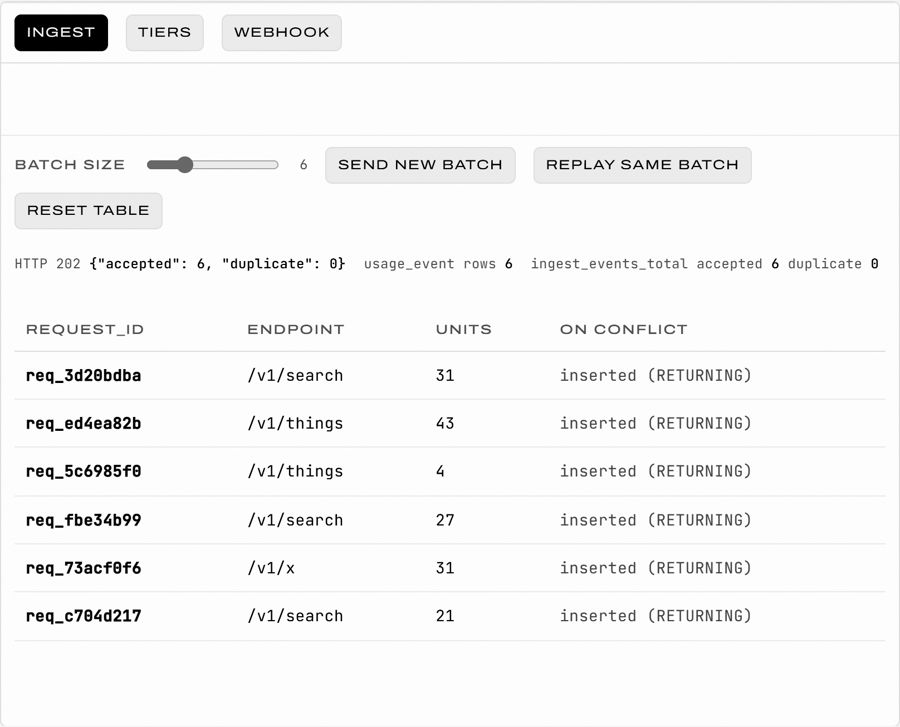 145 tests on live Postgres
Metered API Billing
Usage-based billing where every must-never-happen is a Postgres constraint: idempotent ingest, integer-cent tiers, HMAC webhooks, 145 tests on live Postgres. Case study
Robotics
-
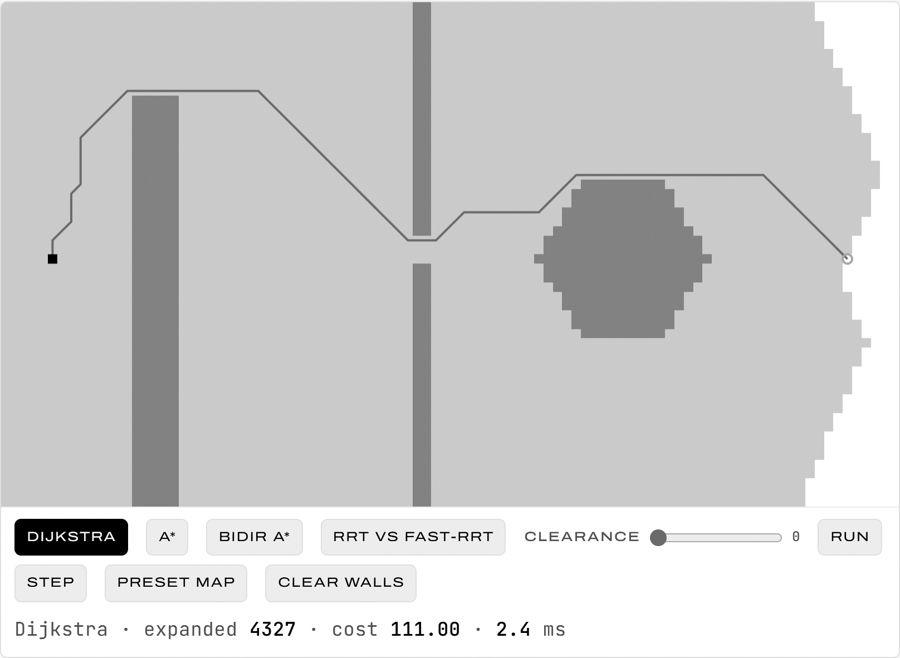
Motion planning and perception
Live path planners you can drag (Dijkstra, bidirectional A*, RRT against Fast-RRT), a perception stack that drove a real TurtleBot3, and YOLO detection on a ROS 2 topic. See the projects -
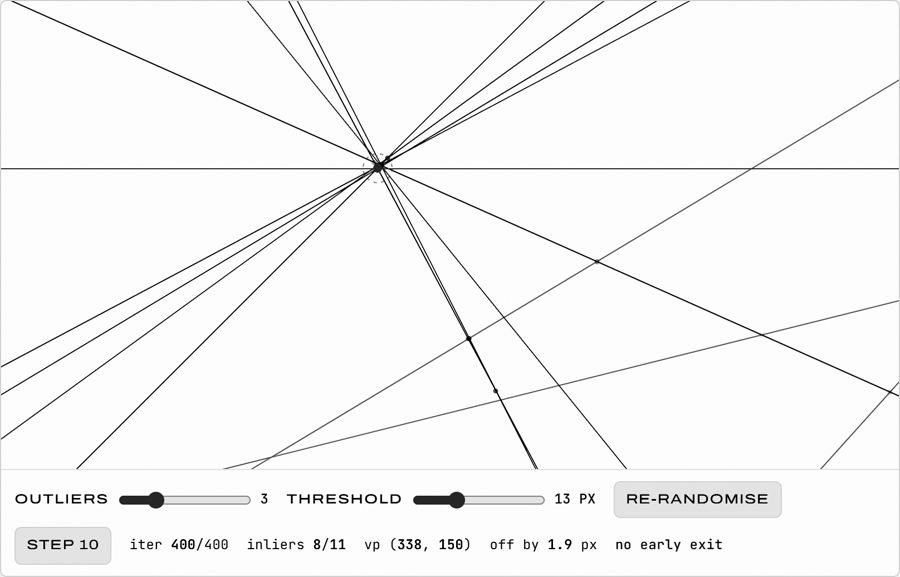
TurtleBot3 perception stack
ROS 2 node: RANSAC horizon, optical-flow and YOLO halts zero the Twist before a homography lane follower steers; ran in Gazebo and on a real TurtleBot3. Case study -
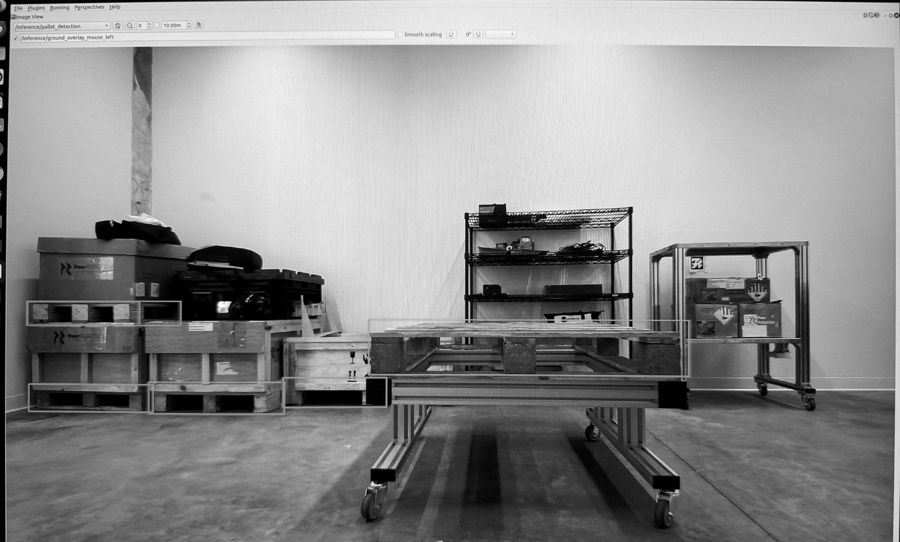 0.966 mask mAP on 133 held-out images
Pallet detection and ground segmentation on ROS 2
Two YOLO11 models, one trained from binary masks, wrapped as ROS 2 Humble nodes; 0.966 mask mAP on 133 held-out images, QoS matched to the rosbag. Read more